Home / Services

Services

Engineering delivered to your specification: design, analysis, simulation and control, by the same team that builds our products. Fixed-scope quotations, clear milestones and complete handover of models, code and documentation.

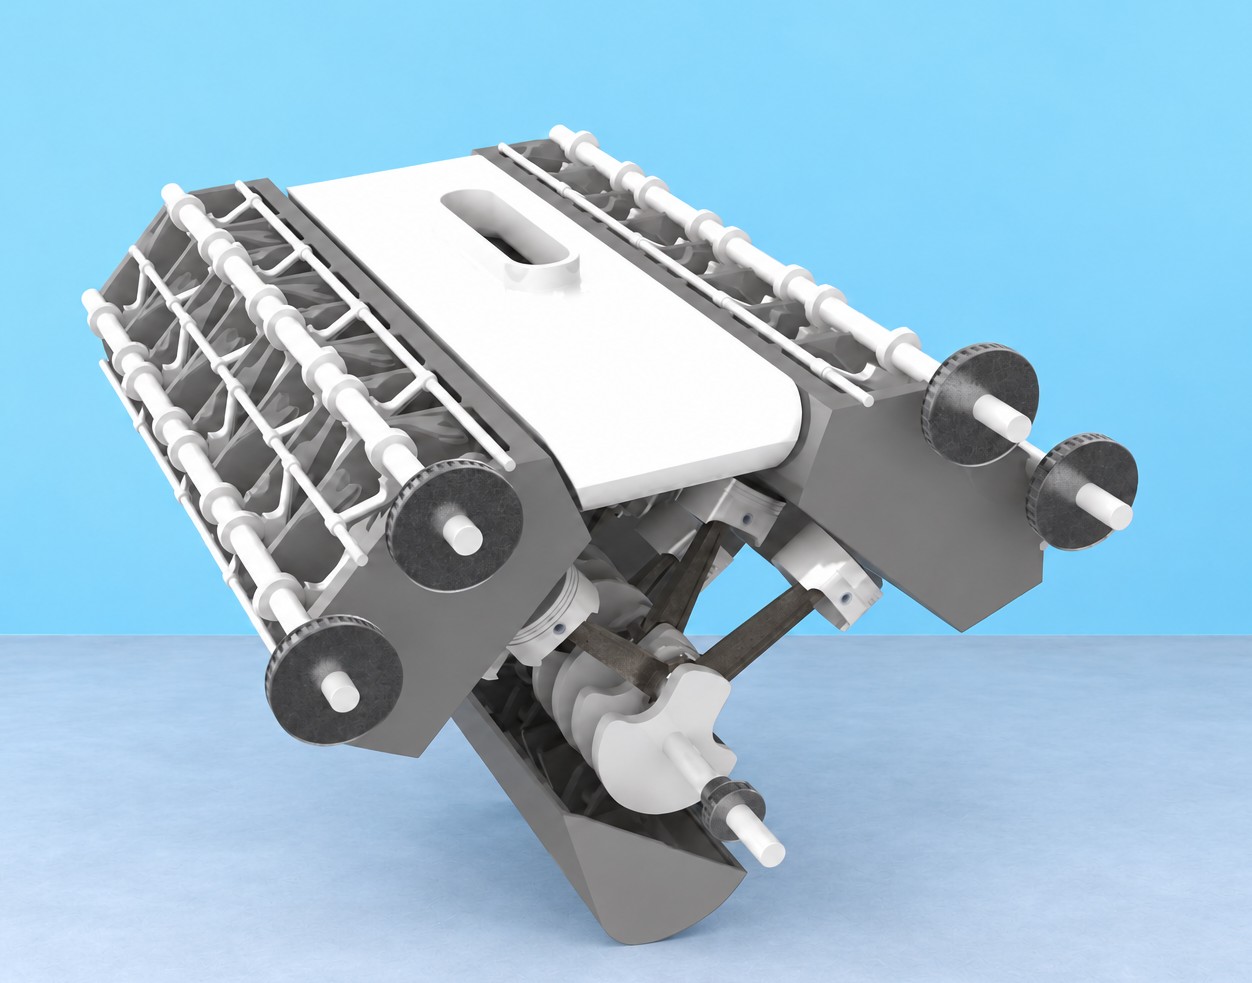
W-16 engine assembly modeled in SolidWorks

CAD & engineering analysis services

Parametric mechanical design in SolidWorks and finite-element analysis in ANSYS, delivered with complete models, results and documentation for research and development projects.

Complex mechanical assembly modeling (W-16 engine example)

Complex mechanical assembly modeling (W-16 engine example)

CAD & FEASolidWorks · ANSYSService

Design and analysis of complex mechanical assemblies as a research-grade engineering service. Our W16 engine study illustrates the depth: a complete multi-cylinder assembly with its crankshaft, connecting rods, pistons and valvetrain modeled parametrically in SolidWorks, with the main load-bearing components analyzed in ANSYS under operating conditions.

Key features

  • Parametric modeling of large, multi-component assemblies with full motion and interference checks in SolidWorks
  • Finite-element analysis of critical components in ANSYS, with documented loads, constraints and mesh-convergence studies
  • Kinematic and dynamic evaluation of the assembly, including loads transferred between components
  • Deliverables: CAD assembly, simulation files, analysis report and documentation suitable for publications and design reviews

Ideal for

Universities and research institutes, graduate research in mechanical design and powertrain engineering, and R&D groups developing complex assemblies.

Options

Scope from a subsystem to a complete assembly, comparative design studies, co-authored technical reports, and training for students and staff on the delivered models.

CAD modeling and finite-element analysis (V6 engine example)

CAD modeling and finite-element analysis (V6 engine example)

CAD & FEASolidWorks · ANSYSService

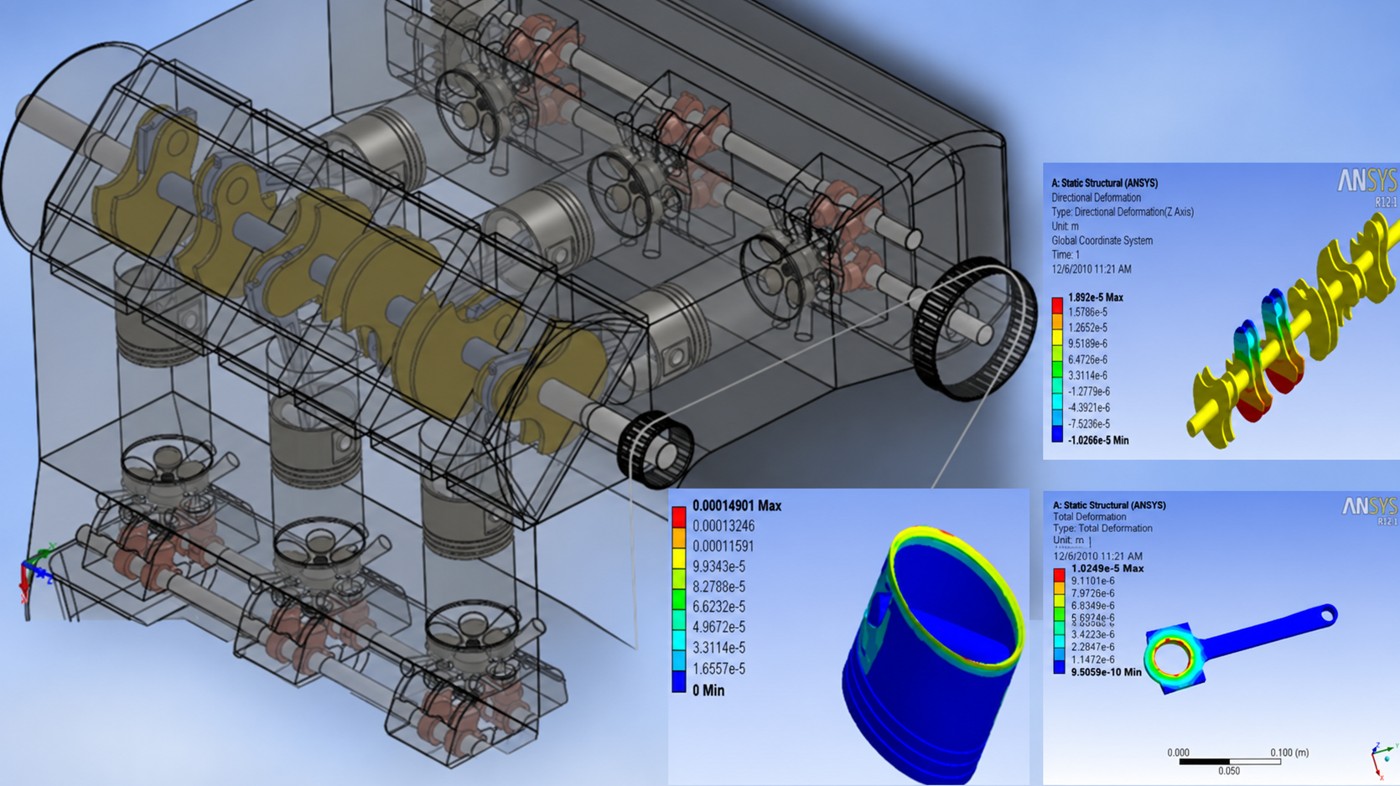
Computer-aided design and finite-element analysis delivered as a research-grade engineering service. Our V6 engine study illustrates the scope: a fully parametric assembly modeled in SolidWorks, with the crankshaft, connecting rod and piston analyzed in ANSYS under operating loads to quantify deformation and stress.

Key features

  • Parametric 3D modeling and assembly of mechanical systems in SolidWorks
  • Static, modal, fatigue and thermal analysis in ANSYS, with documented boundary conditions and mesh-convergence checks
  • Clear reporting of deformation, stress and safety factors, suitable for publications, theses and design reviews
  • Design iterations guided by analysis results, with complete handover of CAD and simulation files

Ideal for

Universities and research institutes, graduate research projects, laboratories validating experimental apparatus, and R&D groups that require analysis-backed designs.

Options

Scope from a single component to a complete assembly, co-authored technical reports, and training for students and staff on the delivered models.

Automation and control services

Simulation-based control-system design for mechanical and mechatronic machines, including ADAMS–Simulink multi-body co-simulation.

Multi-body co-simulation and control

Multi-body co-simulation and control

Multi-body dynamicsADAMS · MATLAB-SimulinkService

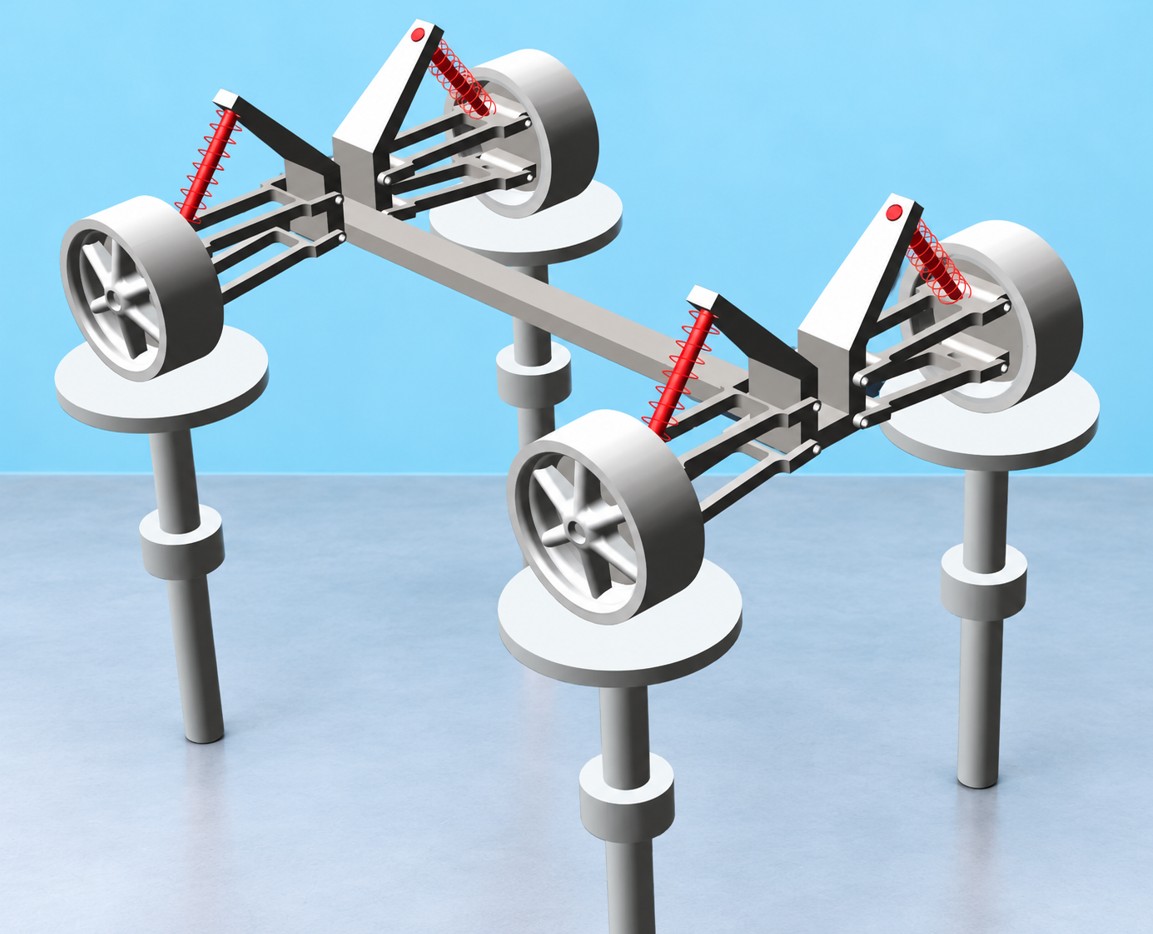
Simulation-based design of control systems for mechanical and mechatronic machines. Our active-suspension study is a representative example: the vehicle is modeled in SolidWorks and ADAMS, the controller runs in MATLAB-Simulink, and the two are co-simulated so that the controller is tuned on the full nonlinear dynamics rather than on a simplified model.

Key features

  • Multi-body model in ADAMS, built with the Mechatronics plugin and co-simulated with MATLAB-Simulink
  • Controller design and tuning, from PID to nonlinear and optimal methods
  • Performance evaluation on simulated response metrics such as ride comfort, settling time and stability margins
  • Deliverables: co-simulation project, controller models, tuning report and documentation

Ideal for

Universities and research institutes, graduate projects in vehicle dynamics and control, and R&D groups evaluating control strategies before committing to hardware.

Options

Alternative plant models (full vehicle, half-car or robotic mechanisms), comparative controller studies, and co-authored technical reports.

Robotics engineering services

Modeling, simulation and controller design for serial manipulators, delivered as complete MATLAB-Simulink and SolidWorks models that you own.

Six-axis manipulator simulation and control

Six-axis manipulator simulation and control

6-DOF manipulatorsSolidWorks · SimMechanicsService

Simulation-based modeling, control and state estimation for six-axis industrial manipulators. Our PUMA 560 study is a representative example: the arm is modeled in SolidWorks and MATLAB SimMechanics, controlled with feedback linearization, and its joint states are estimated with a Kalman filter, with the complete loop designed and evaluated in simulation.

Key features

  • Full kinematic and dynamic model of a 6-DOF arm, from Denavit–Hartenberg parameters to a SimMechanics multibody model
  • Feedback-linearization control combined with a Kalman-filter observer for noisy or incomplete joint measurements
  • Trajectory tracking, payload and joint-limit studies evaluated on simulated motions
  • Deliverables: CAD files, Simulink models, controller and observer code, simulation results and documentation

Ideal for

Universities and research institutes, graduate projects in robot dynamics, control and estimation, and R&D groups evaluating controllers before working with hardware.

Options

Other manipulator architectures, alternative observers and controllers, trajectory planning, and co-authored technical reports.

Serial manipulator simulation and control

Serial manipulator simulation and control

3-DOF manipulatorsSolidWorks · SimMechanicsService

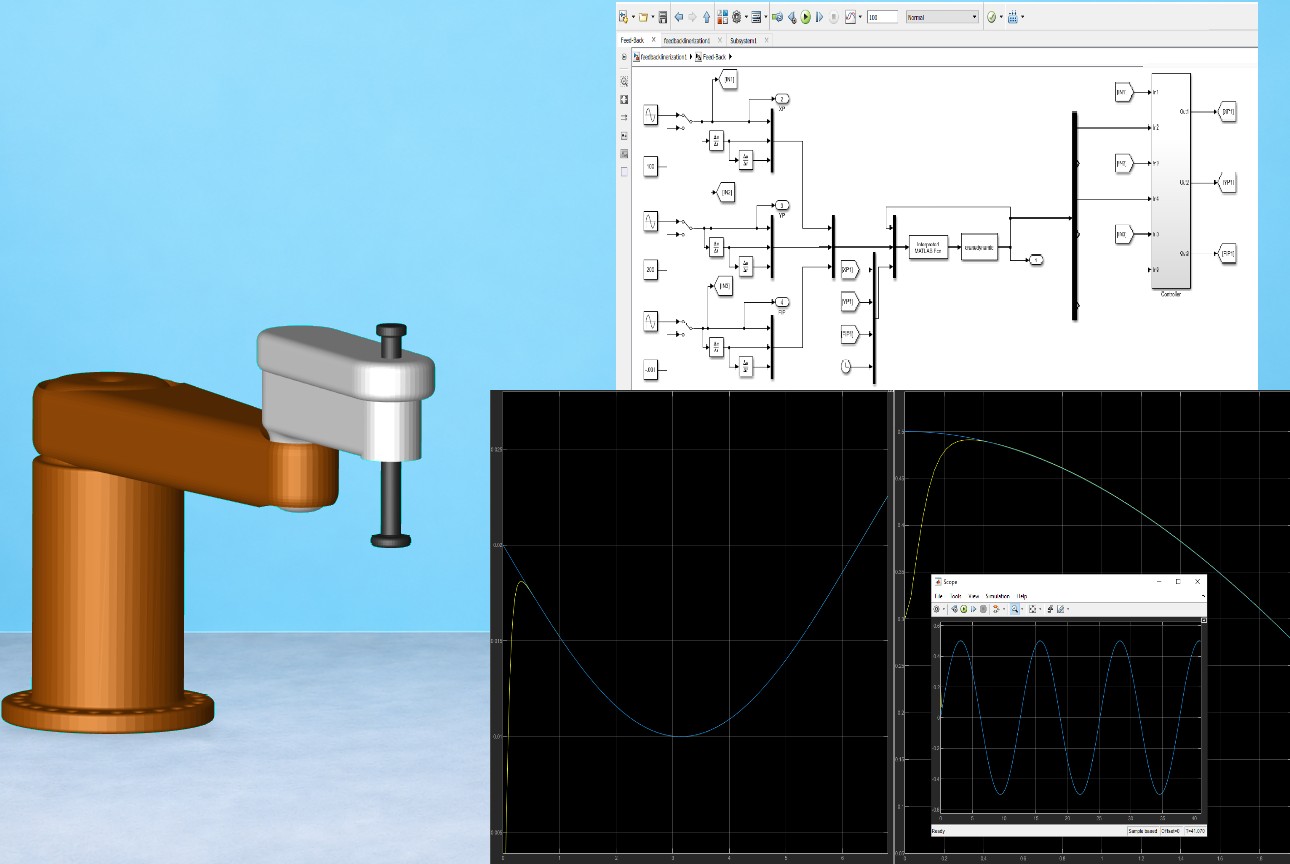
Simulation-based modeling and control design for serial manipulators. Our SCARA study is a representative example: the 3-DOF arm is modeled in SolidWorks, imported into MATLAB SimMechanics with its joints, sensors and actuators, and controlled in closed loop with a feedback-linearization controller tuned entirely in simulation.

Key features

  • Parametric CAD model of the manipulator in SolidWorks, exported to MATLAB SimMechanics
  • Forward and inverse kinematics, dynamic model and workspace analysis
  • Controller design and tuning (feedback linearization, PID and model-based methods), verified on simulated trajectories
  • Deliverables: CAD files, Simulink models, controller code, simulation results and documentation

Ideal for

Universities and research institutes, graduate projects in robotics and control, and laboratories preparing a controller before hardware is available.

Options

Other serial architectures and degrees of freedom, comparative controller studies, trajectory planning, and co-authored technical reports.
Healthcare engineering services

Diagnostic and analysis software, anatomical phantoms and procedural simulators developed with clinicians around a defined clinical need.

Looking for engineering support on a project?

Get a quotation
Get a quotation