Electro-pneumatic Delta robot
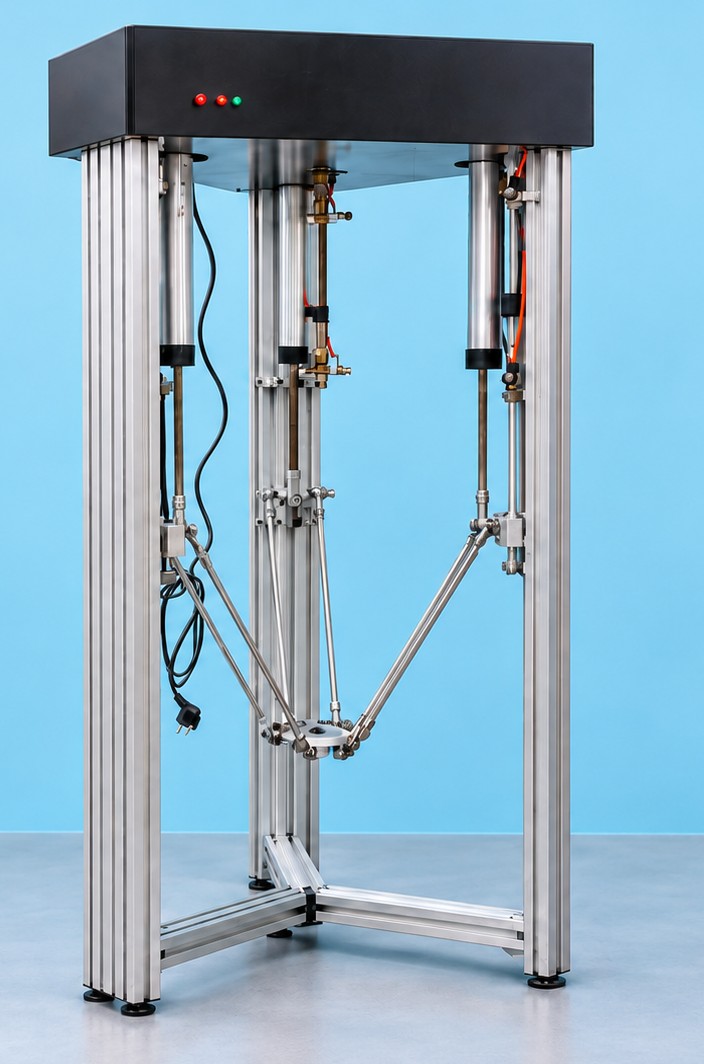
A fast, high-payload Delta robot driven by three electro-pneumatic actuators instead of electric motors, so it moves heavier loads at the same speed and cost class as conventional desktop Deltas. Built for pick-and-place research, controller benchmarking and motion-tracking studies.
Key features
- Three electro-pneumatic actuators for significantly higher payload than electric Deltas
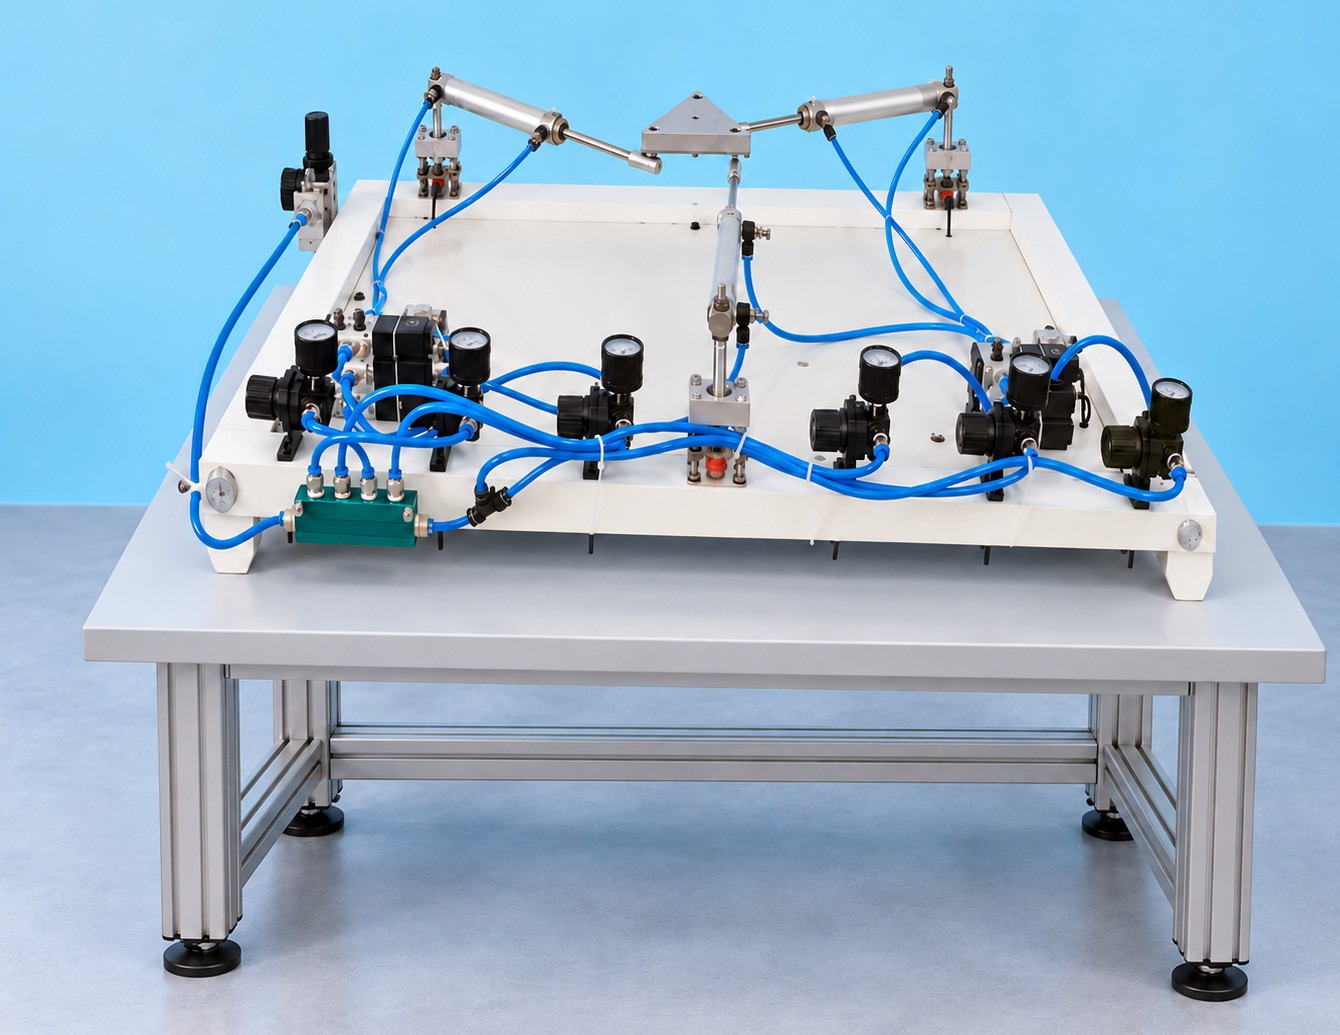
- Six fast 2/3 on-off solenoid valves per actuator for precise, rapid trajectory tracking
- Open control: MATLAB-Simulink, LabVIEW or Python, with ready-to-use examples
- Delivered assembled and calibrated, with CAD files, wiring diagrams and user manual
Ideal for
Robotics and control laboratories, pneumatic-actuation research, automated handling of heavier items, graduate teaching.
Options
Workspace size, payload rating, end-effector (gripper, suction, tool plate), vision add-on, pneumatic supply package.