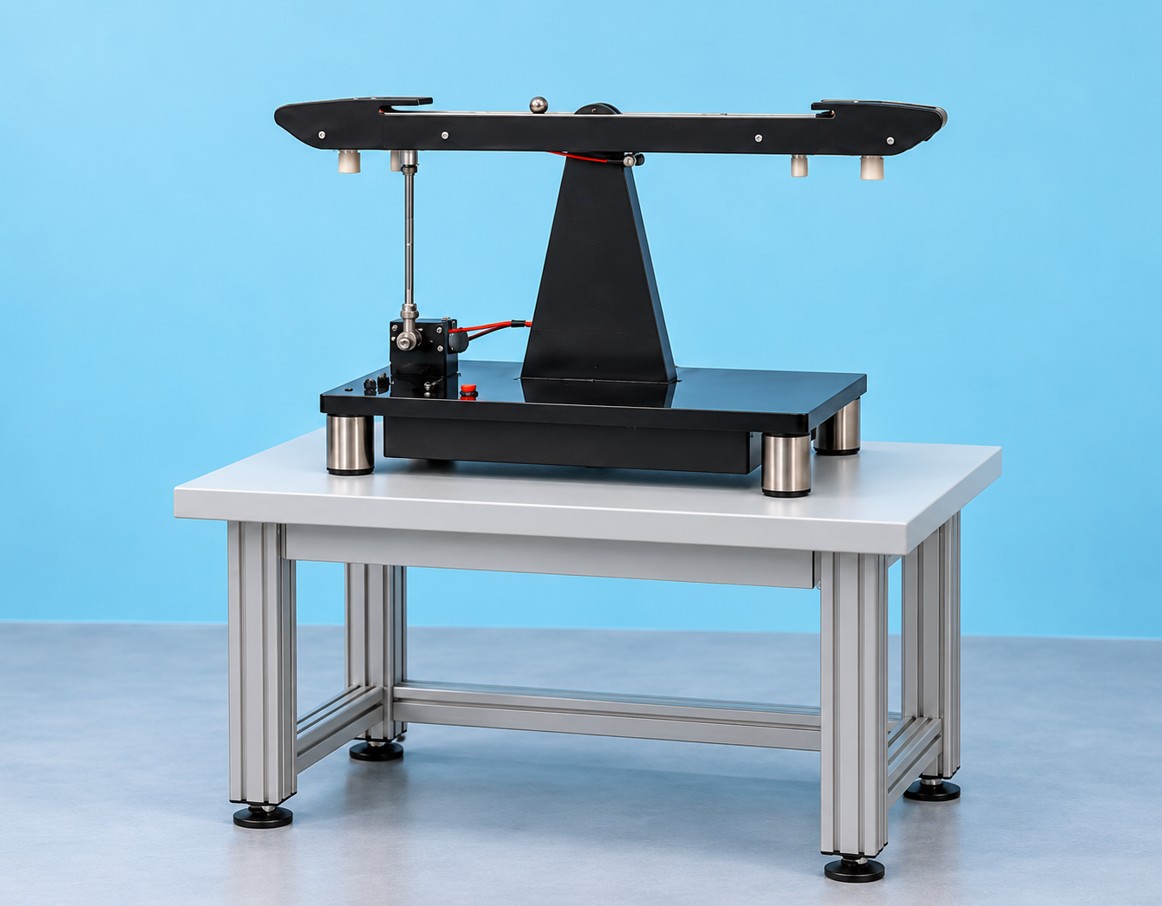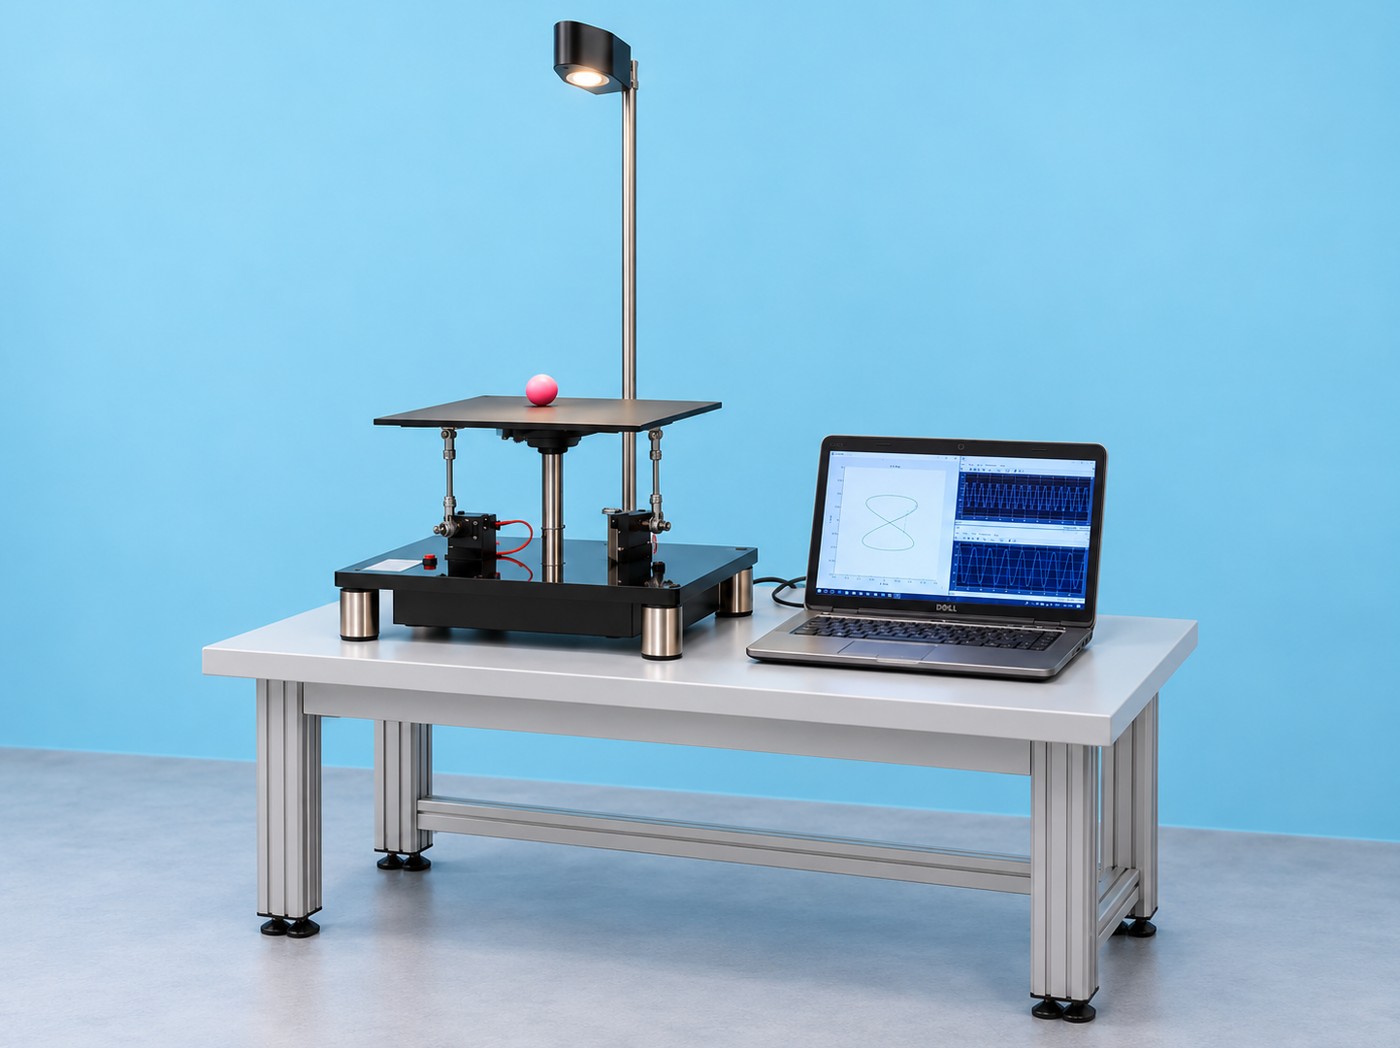
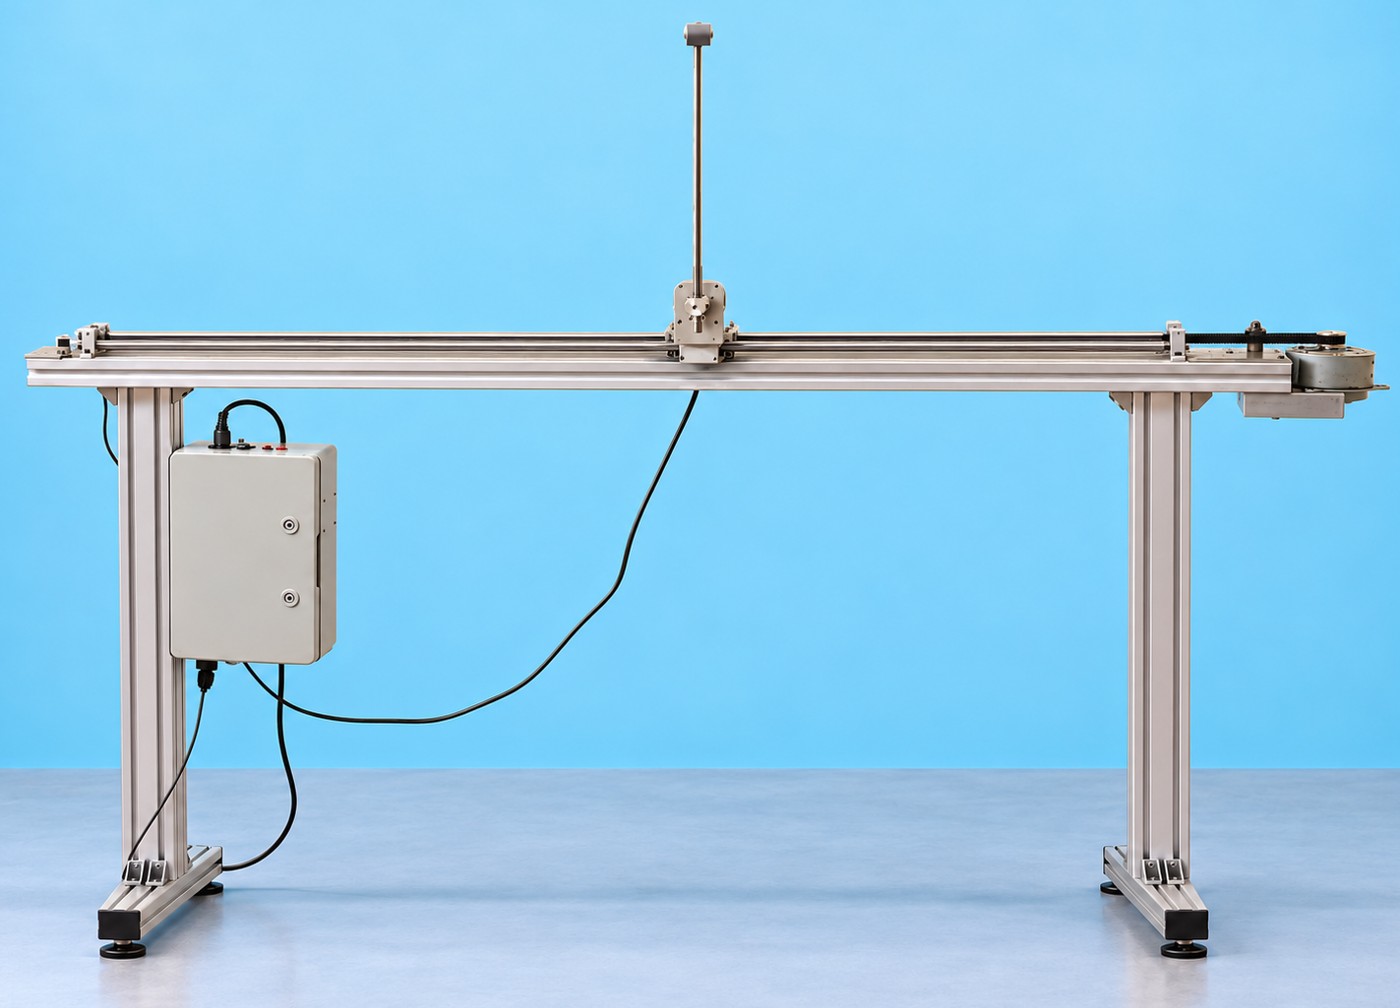
Single and double inverted pendulum
The classic benchmark for under-actuated control, built as a robust cart-pole system that upgrades from single to double or triple pendulum as your course or research advances. Students design a controller in Simulink in the morning and watch it balance real hardware in the afternoon.
Key features
- Cart driven by a DC motor through a timing belt for smooth, backlash-free motion
- Two optical rotary encoders measure cart position and pendulum angle
- Runs directly from MATLAB Simulink Real-Time; example PID and sliding-mode controllers included
- Modular pendulum arm: upgrade to double or triple pendulum without replacing the base
- Lab manual with exercises for undergraduate and graduate courses
Ideal for
Control-engineering teaching labs, research on under-actuated and nonlinear control, demonstration units for open houses.
Options
Single, double or triple configuration, rail length, data-acquisition interface, number of student stations, curriculum package.